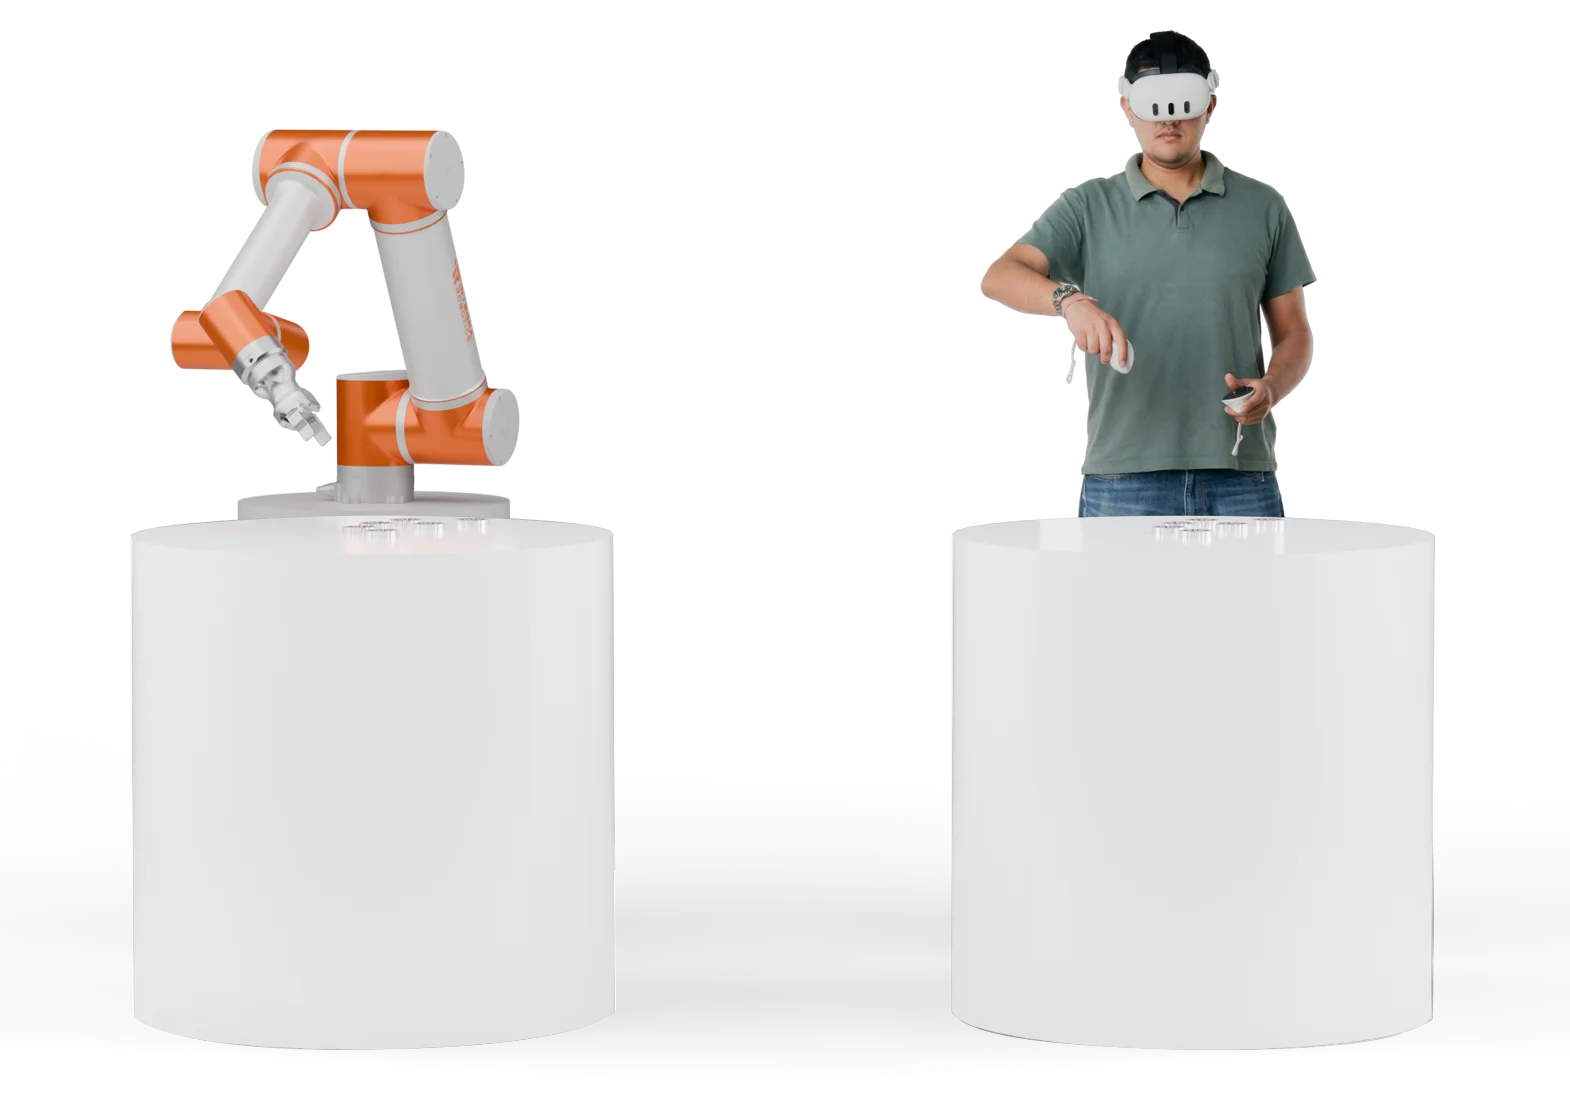
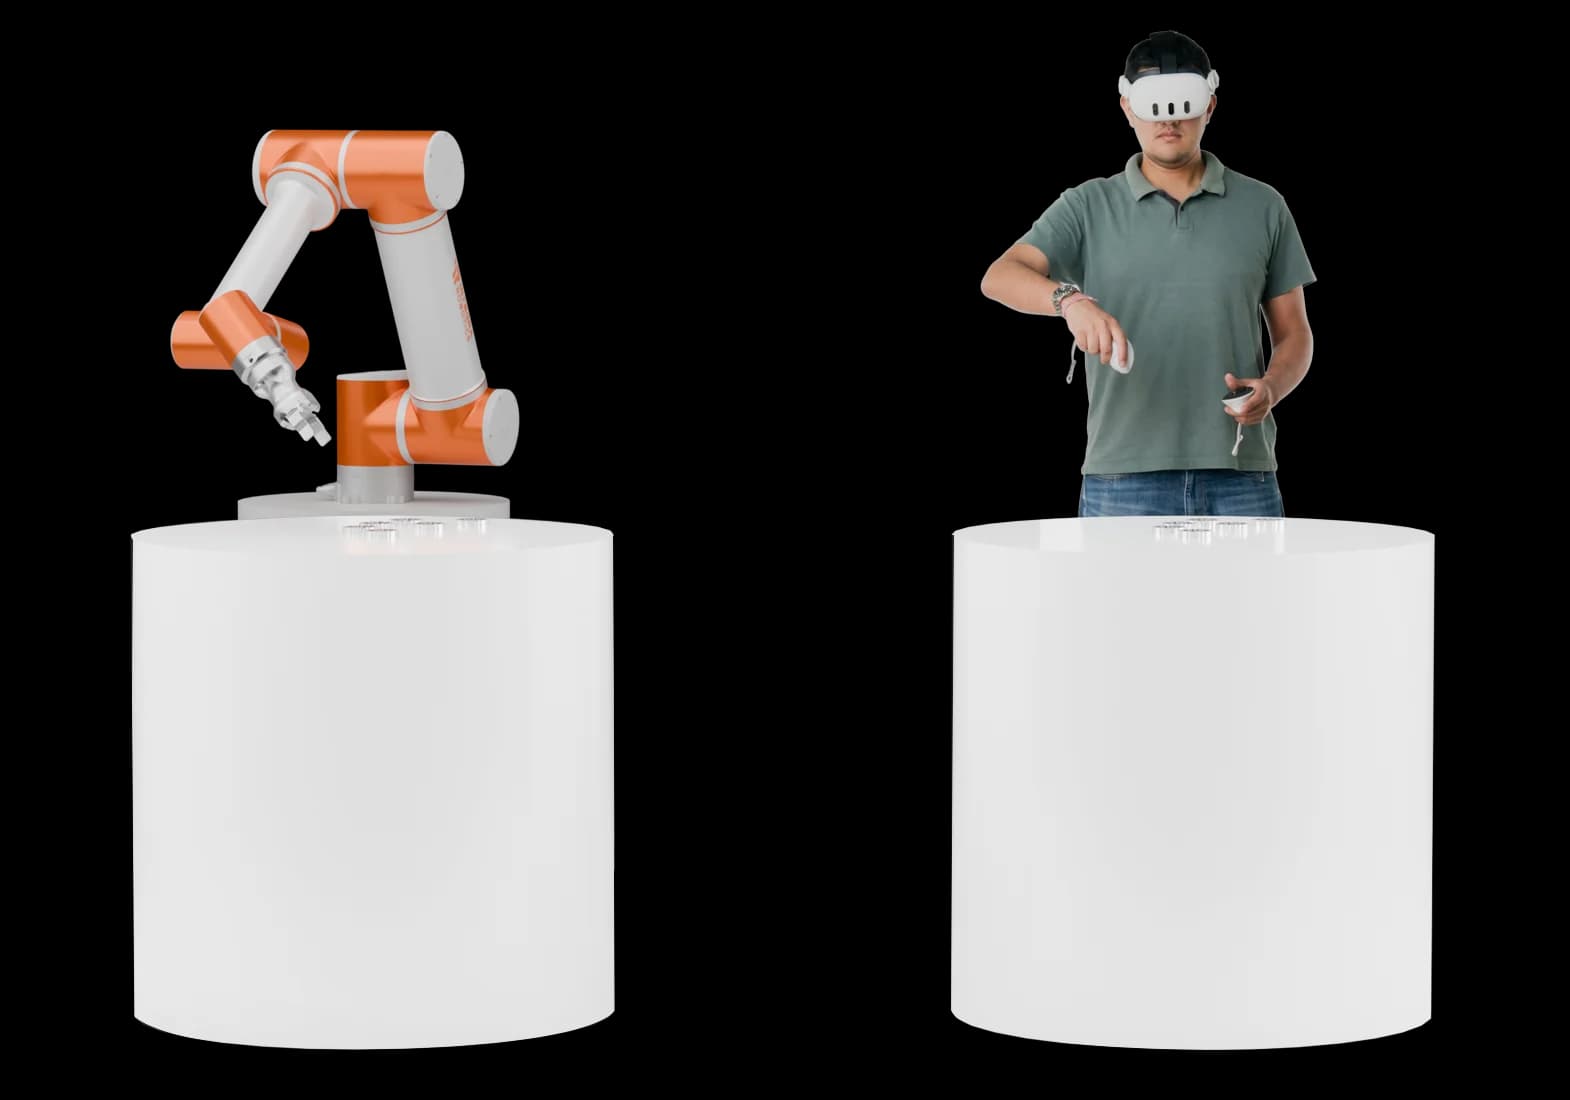
Hardware + software for your data collection. Capture task variation, contact dynamics, and recovery for physical AI agents — operate a 6-axis arm through VR controllers, hand tracking, or sensor gloves while video, joint feedback, and commands are recorded through our SDKs.
Granted Indian Patent
IN597459 B1
TECHNICAL SPECIFICATIONS
Arm, control, signal, and software parameters — the signals behind every action, captured through your workflow.
Robot Arm
6 axes, 3 kg rated payload, 600 mm reach
Communication
Ethernet TCP/IP + Modbus TCP
Indicative Latency (Wired Controller Mode)
~50 ms
Indicative Latency (Hand Tracking / NLOS)
~100 ms
Execution Rate
240 Hz (design target)
Control Modes
Controller mode, hand-tracking mode, or sensor gloves + mode
End-Effectors
Parallel gripper, tripod gripper, or bionic hand
Connectivity
Wired connection or wireless connection
Arm Stream
Joint position, velocity and tool pose · Extended: torque, current, temperature*
End-Effector Stream
Opening, force and current* · Extended: selected tool and sensor interface
Vision Stream
Wrist RGB-D + frame timestamps · Extended: front RGB, audio, force/torque*
Intent + Outcome Stream
Requested / applied action, task result · Extended: retries, aborts and recovery
Capture Priorities
Time alignment, traceability, native rates
Manipulation Data
Joint motion, tool pose, grip feedback** · How: arm + tool SDKs
Environment Data
RGB-D, lighting, clutter, viewpoint variation · How: wrist camera + optional scene sensors
Operations Data
Commands, timing, retries, task outcomes · How: log SDK commands; add your outcome labels
Included in Every Package
3 kg / 600 mm, 6-axis arm; control box, pendant + cables; VR headset + controllers; wrist RGB-D camera; edge computer + accessories; robot feedback + operator SDKs
Software-Only Tele-op
1 user / 3 robotic arms / SDK on your Windows system
Software Inputs
Live RGB + stereo; sensor streams + robot state
Software Feedback
Force/torque, contact, haptics + collision proximity; VR feedback visualisation
Software Outputs
Commands, trajectories, logs + recordings; operator-provided quality labels
Safety
Safety stays local — robot limits remain independent of the network connection
Certifications
ISO 9001 Quality · ISO 10218 Robot safety · ISO 13850 Emergency stop · ISO 27001 Information security
Patent
Granted Indian Patent · IN597459 B1
Program
NVIDIA Inception Program
*Where exposed by selected hardware. **Feedback depends on the selected hardware and interfaces.
Capture rates and timing tolerances agreed at commissioning. Latency is indicative — verify command, feedback and video delay separately during commissioning.
Software-only option: client supplies hardware; sensor functions depend on connected devices.
YOUR CAPTURE WORKFLOW
Integra supplies the hardware, software, and SDK interfaces. Your team operates, records, labels, validates, and exports.
Hands, controllers or sensor gloves. Immersive robot control with VR + gesture operation.
Requested command + applied action. Safety stays local — robot limits remain independent of the network connection.
Log video, joint feedback and commands. Capture priorities: time alignment, traceability, native rates.
Your team labels, validates and exports. Hardware + software supplied by Integra; capture led by your team.
PHYSICAL AI DATA CAPTURE
If your team needs expert demonstrations with real task variation, contact dynamics, and recovery behaviour — manipulation data, environment variation across lighting, clutter, and viewpoint, and operational logs with task outcomes — the tele-operation platform was built for you.